Subject:
|
Re: Pneumatic hexapod omni-Directional 2 (repost)
|
Newsgroups:
|
lugnet.technic, lugnet.robotics
|
Date:
|
Sun, 1 May 2005 21:29:57 GMT
|
Viewed:
|
898 times
|
| |

|
|
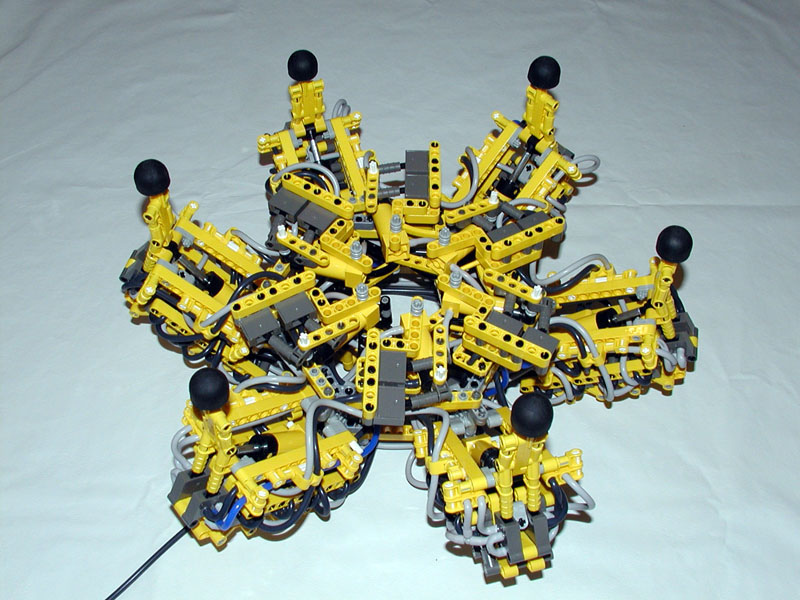
That is awesome. Could you put a vid of it in action. I love the style
- it is functional, but equally stylish - the way you have arranged
the cabling makes it look really something. I can really imagine that
as a spider tank model looking rather fantastic.
Could you do a pneumatic logic diagram of it? There are so many
connections there - I am pretty bewildered after trying to follow what
went where - I imagine it is segmented, and with a couple of sections
- each leg is basically the same in relation to the previous leg (or
another leg depending on the gait set up).
Anyway - thoroughly amazed at it!
Danny
--
http://orionrobots.co.uk - Build Robots
On 5/1/05, Kevin L. Clague <kevin_clague@yahoo.com> wrote:
> I uploaded some pictures of PhD 2, that some of you saw at BrickFest 2004.
>
> PhD2 is a neat and tidy version of its predecessor Hex-363.
>
> PhD2 can adjust the sweep direction of each of its legs, allowing to walk any
> of
> six directions (forward, forward right, forward left, backward, backward
> right,
> backward left), and can turn right and left. It can even walk forward/reverse
> with one triple leg group, and turn with the other triple leg group. PhD2 can
> also walk in place.
>
> It has no gravity well, meaning that in general the body does not move up and
> down as it walks. It does this by making sure that all legs are on the ground
> before lifting any.
>
> This is my most expensive MOCs so far. It has 12 switches and two pistons per
> leg. Plus a few more pistons/switches for timing control.
>
> Enjoy!
>
> http://www.brickshelf.com/gallery/kclague/PhD2
> http://www.brickshelf.com/gallery/kclague/PhD2/p9090189.jpg
> http://www.brickshelf.com/gallery/kclague/PhD2/p9090194.jpg
>
> Kevin
>
> (I posted this to annouce.moc, but forgot to post it here)
>
|
|
Message has 1 Reply:
Message is in Reply To:
6 Messages in This Thread:
   

- Entire Thread on One Page:
- Nested:
All | Brief | Compact | Dots
Linear:
All | Brief | Compact
This Message and its Replies on One Page:
- Nested:
All | Brief | Compact | Dots
Linear:
All | Brief | Compact
|
|
|
|